Read the research
RoboJev: An Open Vision-Language Judge for Robot Success Detection
Josef Chen · October 2026
Unsubmitted manuscript
What’s inside
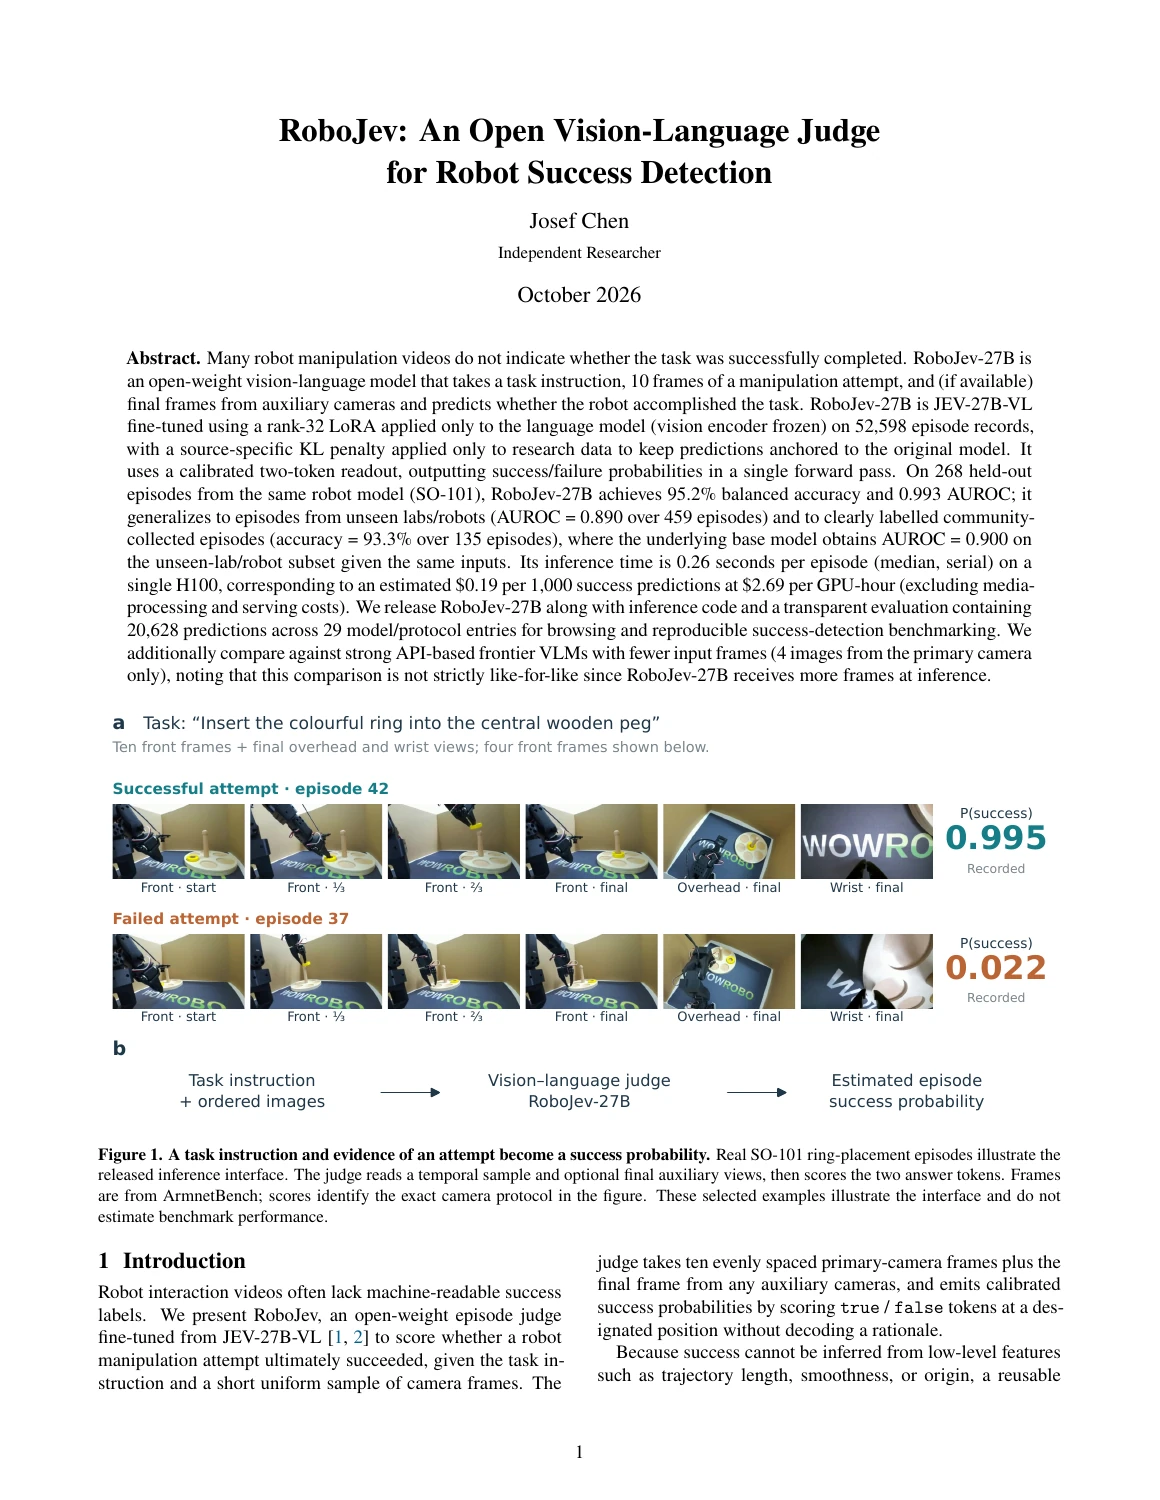
The paper describes the model, training sources, calibration and evaluation across SO-101, unseen labs and community robot recordings.
It also reports the limits of the comparisons: unequal frame counts, uncertainty around accuracy differences, ambiguous outcomes and cases where the ten-frame base model matches the fine-tuned model.
Download the reproducibility package or inspect individual recorded answers.
Cite the paper
@unpublished{chen2026robojev,
  author = {Chen, Josef},
  title = {{RoboJev: An Open Vision-Language Judge for Robot Success Detection}},
  year = {2026},
  month = oct,
  institution = {Independent Researcher},
  url = {https://robo-jev.com/paper/RoboJev.pdf},
  note = {Unsubmitted manuscript. No arXiv identifier or DOI has been assigned.}
}
No arXiv identifier or DOI has been assigned. Download BibTeX.